Cornell Bowers College of Computing and Information Science Cornell
Bowers
Symbiotic Computing Initiative Physical AI for Society

The future of physical AI is symbiotic.

Humans, robots, and machines working in symbiosis to help each other solve some of the most important societal challenges—in homes, on farms, in classrooms, and on factory floors.

Building the computing stack underneath is a decade of research. We are doing it in the open, with the companies who will build on it.

White paper Build with us Open-source Seminar News and events

The Symbiotic Computing Stack

Building this stack will take researchers and practitioners in computer systems, machine learning, robotics, sensing, law, and occupational therapy working in symbiosis. Click on any layer to learn more about projects.

Symbiotic applications

Rachit AgarwalRA Tapomayukh BhattacharjeeTB Mark CampbellMC Tanzeem ChoudhuryTC Manoj KarkeeMK Joel SteinJS Mabel TaracenaMT
Human care Industrial Agriculture Education

Symbiotic control

Rachit AgarwalRA Tapomayukh BhattacharjeeTB Mark CampbellMC Sarah DeanSD Chris De SaCD Bharath HariharanBH

Symbiotic planning

Rachit AgarwalRA Tapomayukh BhattacharjeeTB Mark CampbellMC Sarah DeanSD Chris De SaCD Bharath HariharanBH

Symbiotic perception

Tapomayukh BhattacharjeeTB Mark CampbellMC Chris De SaCD Bharath HariharanBH

Symbiotic data

(collection, simulation,
archive, replay)
Rachit AgarwalRA Mark CampbellMC Tanzeem ChoudhuryTC Udit GuptaUG

Robot OS and runtime

Rachit AgarwalRA Chris De SaCD Udit GuptaUG

Compute and hardware

(compute, memory, sensors, actuators, bodies)

Symbiotic sensing

Tapomayukh BhattacharjeeTB Tanzeem ChoudhuryTC

Symbiotic trust and safety

Rachit AgarwalRA Tapomayukh BhattacharjeeTB Mark CampbellMC Karen LevyKL

Symbiotic evaluation

Rachit AgarwalRA Tapomayukh BhattacharjeeTB Udit GuptaUG Karen LevyKL

Every component is learned — driven by machine learning rather than hand-written rules. Compute and hardware is drawn dashed because we do not plan to innovate there, for now. Trust and safety, and evaluation, run the full height because they constrain and measure everything above them.

The entire stack builds on existing open-source projects. Everything we build returns to the open-source community.

Symbiotic Computing Deployments

Symbiotic evaluation will build upon and extend three systems that our team has taken out of the lab and deployed in the wild: homes, commercial orchards, and public roads.
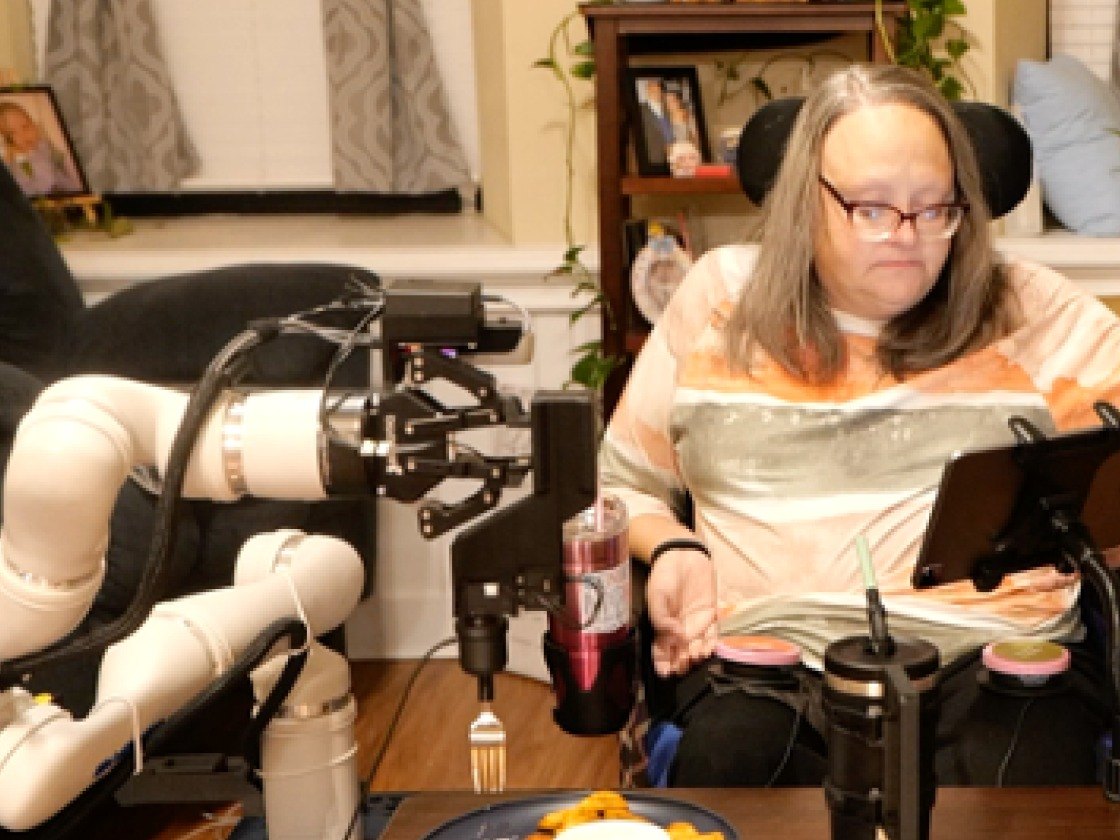
A care recipient using the FEAST mealtime-assistance robot at home

Care: mealtime assistance in the home

FEAST lets care recipients personalize the robot themselves. We built it over three years of participatory design with Aimee, who has multiple sclerosis, and Benjamin, who has a spinal cord injury, then ran it in their own homes with minimal researcher intervention. A formative study with 21 care recipients surfaced 46 distinct personalization needs: bite size, approach angle, when to ask rather than act. The lesson was that deployment success turns not on more autonomy, but on whether the user can re-parameterize the robot without researcher intervention.

Two private homes · Three-year co-design
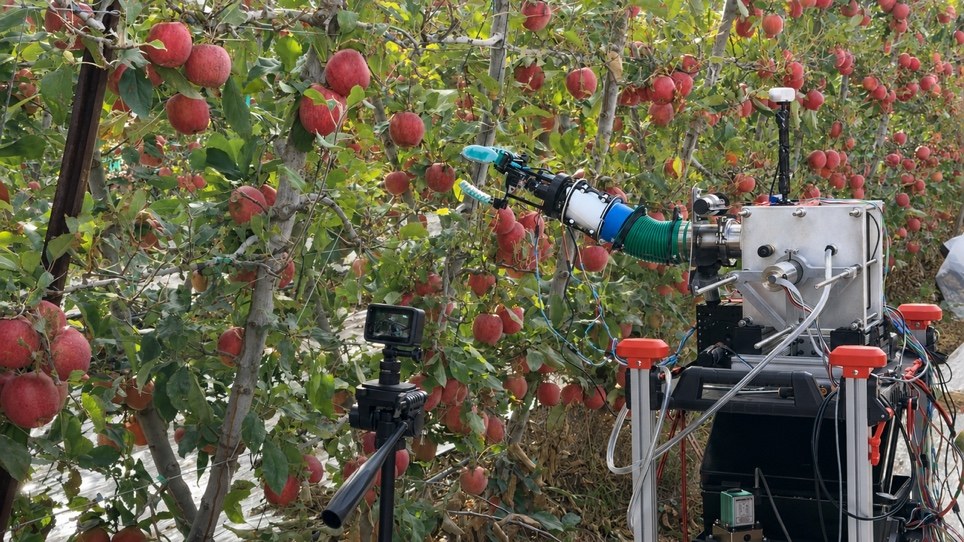
A robotic apple harvester with a soft manipulator picking fruit in a fruiting-wall orchard

Agriculture: apple harvesting in commercial orchards

Fifteen years of machine-vision systems, end-effectors, and integrated harvesting robots, rigid and soft, tested in university and commercial orchards in New York and Washington across a wide range of cultivars and canopy architectures. The field located the boundary. Robots pick accessible fruit very effectively; fruit in clusters, or occluded by branches and foliage, remains the open problem. Commercial deployability runs through multi-arm coordination and human–robot collaboration on canopy perception, planning, and manipulation.

NY & WA orchards · Fifteen years of field studies
The same Ithaca street seen across six different weather and light conditions

Mobility: all-weather perception on public roads

An instrumented vehicle drove the same 15 km route through Ithaca hundreds of times over fifteen months, through sun, rain, snow, night, and traffic, capturing high-density lidar, camera, and GPS/inertial data with amodal annotations for partially occluded objects. Repetition was the instrument: one route driven hundreds of times turns weather, light, and season into controlled variables, which no single-pass collection can do. Released as the Ithaca365 dataset (ithaca365.mae.cornell.edu, CVPR 2022), it remains in community use for perception in low light and adverse weather. The rig has since collected in Hanoi.

Ithaca, NY & Hanoi · Fifteen-month longitudinal collection
Symbiotic Computing Seminar

A weekly seminar on physical AI for society, open to Cornell and to our industry partners.

25 Aug 2026 Introduction to the Symbiotic Computing Initiative Rachit Agarwal · Tapomayukh Bhattacharjee

Symbiotic Computing News

2025 FEAST wins the Best Paper Award at RSS 2025
2025 To Ask or Not To Ask is nominated for the Best Paper, Best Student Paper, and Best HRI Paper Awards at ICRA 2025
2024 Feel the Bite is nominated for the Best Systems Paper Award at HRI 2024
2022 RCareWorld wins the Best RoboCup Paper Award at IROS 2022 and is a finalist for the Best Paper and ABB Best Student Paper Awards

Symbiotic Computing Open-source

Open-source releases from across the stack — runtimes, benchmarks, datasets, and reference implementations.

White paper Build with us Browse the org

symbiotic-computing@cornell.edu