Date: November 18, 2026
Speaker: Yu Xiang, The University of Texas at Dallas
Title: Toward Generalizable Robot Manipulation: Cross-Embodiment Learning and Real-World Evaluation
Host: Kuan Fang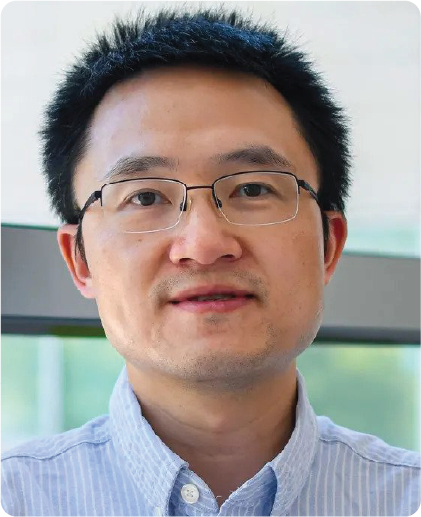
Abstract: Generalization remains a central challenge in robot manipulation. In this talk, I will discuss our recent work addressing two complementary aspects of this challenge: generalization across robot embodiments and evaluation of real-world generalization. First, I will introduce the Unified Hand Action Space (UHAS), which represents dexterous hand actions through deformation of a canonical sphere, enabling policy learning and transfer across substantially different robotic hands. Second, I will present VLA-Replica, a low-cost and reproducible framework for evaluating vision-language-action (VLA) policies under both in-distribution and out-of-distribution conditions. Through evaluations of recent manipulation models, I will discuss their capabilities and limitations in real-world settings. Together, these efforts highlight the importance of both transferable action representations and rigorous real-world evaluation toward more generalizable robot manipulation.
Bio: Yu Xiang is an Assistant Professor of Computer Science at The University of Texas at Dallas, where he leads the Intelligent Robotics and Vision Lab (IRVL). His research focuses on robotics and computer vision, with an emphasis on robot manipulation, robot learning, and generalizable robotic systems. Before joining UT Dallas, he was a Senior Research Scientist at NVIDIA and conducted postdoctoral research at Stanford University and the University of Washington. He received his Ph.D. in Electrical Engineering from the University of Michigan. He is a recipient of the Sony Research Award (2022) and the NVIDIA Academic Grant Program Award (2024). He is an IEEE Senior Member and serves as an Associate Editor for IEEE Robotics and Automation Letters (RA-L).
Homepage: https://yuxng.github.io/

