

Date: October 21, 2026
Speaker: Himani Sinhmar, Princeton University
Title: Simultaneous thinking and acting for safe, adaptive, and resource-aware autonomy
Host: Tapomayukh Bhattacharjee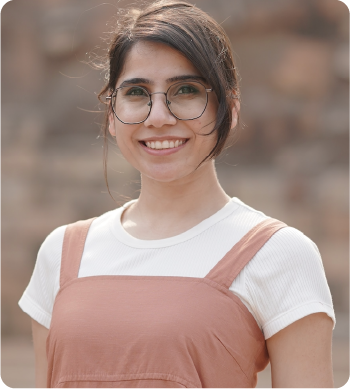
Abstract: As robots enter our physical world, they will inevitably interact with people and other agents whose behavior cannot be fully predicted. Even without a common goal, their decisions and actions influence one another through the shared environment. In highly interactive settings, a fundamental challenge is that the information a robot needs to make intelligent decisions may emerge only through physical interaction and remain useful only briefly. Therefore, acting safely while making timely decisions is central to successful coordination, cooperation, and collaboration.
In this talk, I will introduce neuromorphic decision dynamics (NDD) that let robots proactively shape local interactions to steer emergent behavior toward safe, task-relevant outcomes with limited sensing, computation, and communication. I will demonstrate NDD-based autonomy through provably safe, deadlock-free navigation in dense crowds and coordination among robotic teams monitoring environments such as deep forests. I will close by discussing how principles underlying NDD extend across tasks and embodiments, from warehouse fleets and delivery robots to UAVs and soft robots.
Bio: Himani Sinhmar is a Postdoc at Princeton University, working with Professor Naomi Leonard. She received her Ph.D. in Aerospace Engineering from Cornell University in 2024, advised by Professor Hadas Kress-Gazit, and her bachelor’s and master’s degrees from IIT Bombay. Her research explores how robots can exploit the very interactions that make their surroundings uncertain to adapt on the fly and complete tasks with limited onboard sensing, compute, and communication. She takes a cross-disciplinary approach to robotic autonomy, combining dynamical systems and control theory with insights from neuroscience and collective behavior.