Date: October 28, 2026
Speaker: Yan Chang, NVIDIA
Title: Learning to Act: From Human Experience to Generalist Humanoids
Host: Kuan Fang
Abstract: Generalist humanoids should learn from watching people, anticipate the consequences of their actions, and coordinate their bodies to accomplish new tasks. This talk explores a Real2Sim2Real approach that connects human experience, simulation, and physical action. I will discuss turning human videos into reconstructed interactions and robot training data, learning manipulation through contact, and scaling navigation and whole-body control across embodiments. Drawing on GR00T, Cosmos, and action-conditioned world models, I will examine how prediction, policy learning, and physics-based simulation can support increasingly general capabilities. These complementary advances point toward humanoids that learn from diverse experience, with open challenges in skill composition, generalization, and reliable real-world deployment.
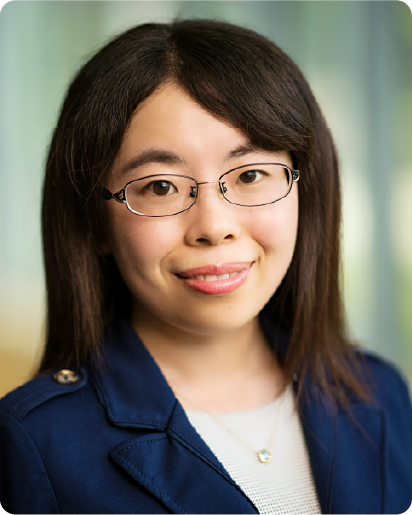
Bio: Yan Chang is a Principal Engineer and Senior Engineering Manager at NVIDIA, where she leads the Isaac loco-manipulation team. Her work spans robot learning, world models, and simulation, with a focus on turning human experience into generalist robot capabilities. Before joining NVIDIA, she led the foundation model team at Zoox, Amazon’s autonomous driving subsidiary. She holds a Ph.D. from the University of Michigan, Ann Arbor.

