Date: September 25, 2026
Speaker: Haozhi Qi, incoming Assistant Professor, University of Chicago
Title: Building dexterity with simulation and human data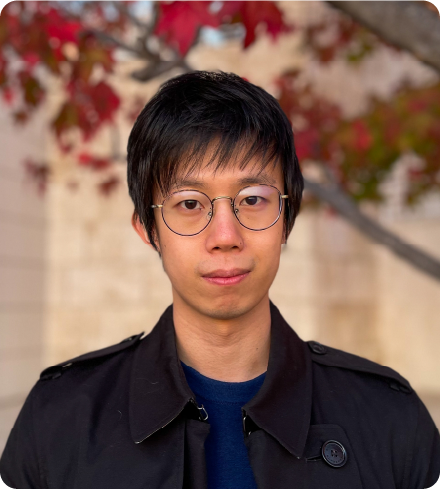
Abstract: Learning dexterous manipulation requires data that captures coordinated finger motion and contact-rich interaction. Such data is difficult to collect: directly teleoperating robot hands is challenging, simulation can only approximate real contact and sensing, and human videos lack robot action labels and direct measurements of contact forces. In this talk, I will discuss how simulation and human data can address these limitations together. I will first show how skills learned in approximate simulation can assist teleoperation, enabling humans to collect real-world demonstrations for training tactile-aware policies. I will then describe how physics-informed retargeting and reinforcement learning turn human motion into executable robot behavior. Finally, I will introduce a tactile glove that records contact information during human demonstrations and supports transfer to robots. Through examples of dexterous manipulation and tool use, I will argue that progress depends on designing data collection and learning methods around the complementary strengths of simulation, robot experience, and human demonstrations.
Bio: Haozhi Qi is a Member of Technical Staff at Amazon Frontier AI & Robotics (FAR) and an incoming Assistant Professor at the University of Chicago. He received his Ph.D. in Electrical Engineering and Computer Sciences from UC Berkeley. His research focuses on algorithms and systems for dexterous robotic manipulation. He received the Lotfi A. Zadeh Prize and the EECS Evergreen Award for Excellence in Undergraduate Research Mentoring, and was named an RSS Pioneer in 2026. More information is available at at https://haozhi.io.

